// Research
Halfpixel ·
7.8 km without GPS
A bike ride tracked from camera and IMU, built in Rust
Research by Sameh Khamis · 4.0K views on X
// The post
 Sameh Khamis@sameh_khamis · Co-founder and CTO, Halfpixel
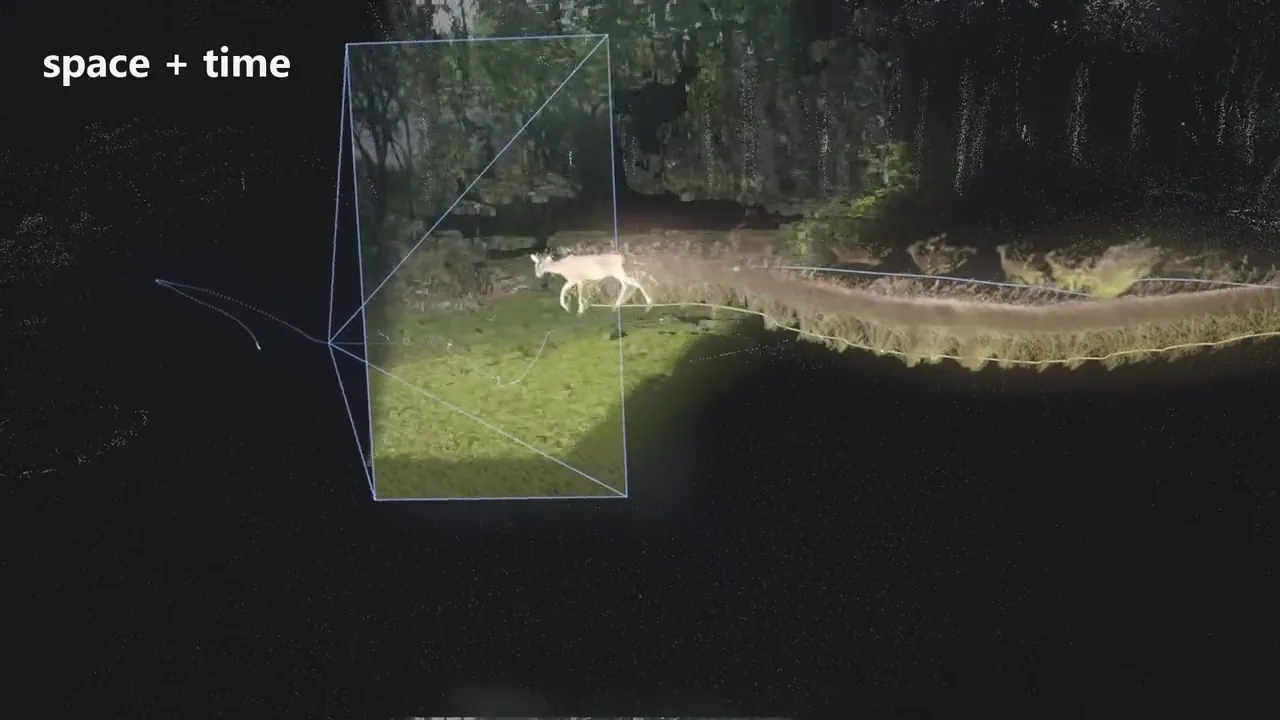
Tracked a 7.8 km bike ride with an Insta360 X5 at ~40 fps!
Built ARKit-style VIO with loop closure in Rust (surprise!) - total ride ATE is 105 m RMSE on 7.8 km.
From the Insta360 images + IMU to my Android phone, no mapping, no GPS, but that'd have helped with the scale!
- Visual-inertial odometry
- Loop closure
- Rust
- Insta360 X5
- 7.8km
- ride tracked
- ~40fps
- tracking
- 105m
- RMSE over the ride
- 0
- GPS or map used
What it means
The numbers are from Sameh's post.
- Result
- 7.8 km tracked at about 40 fps. Total error over the ride is 105 m RMSE.
- Inputs
- Insta360 X5 images and IMU, sent to an Android phone. No mapping and no GPS.
- Why it matters
- A camera can work out where it has been on its own, which is how footage gets placed on a map.
See what it's for
Real events, replayed in God's Eye View.